ML + robotics research
UAV Sandbox
A simulation platform for testing how drones sense obstacles, assess risk and plan routes.
- My role
- Experiment design, sensor pipelines and ML tooling
- Output
- Simulation platform and repeatable experiments
- Tools
- Python · PX4 / Gazebo · PyTorch / ONNX
- Status
- Active research · Simulation only
Case study updated 2 October 2026
What I built
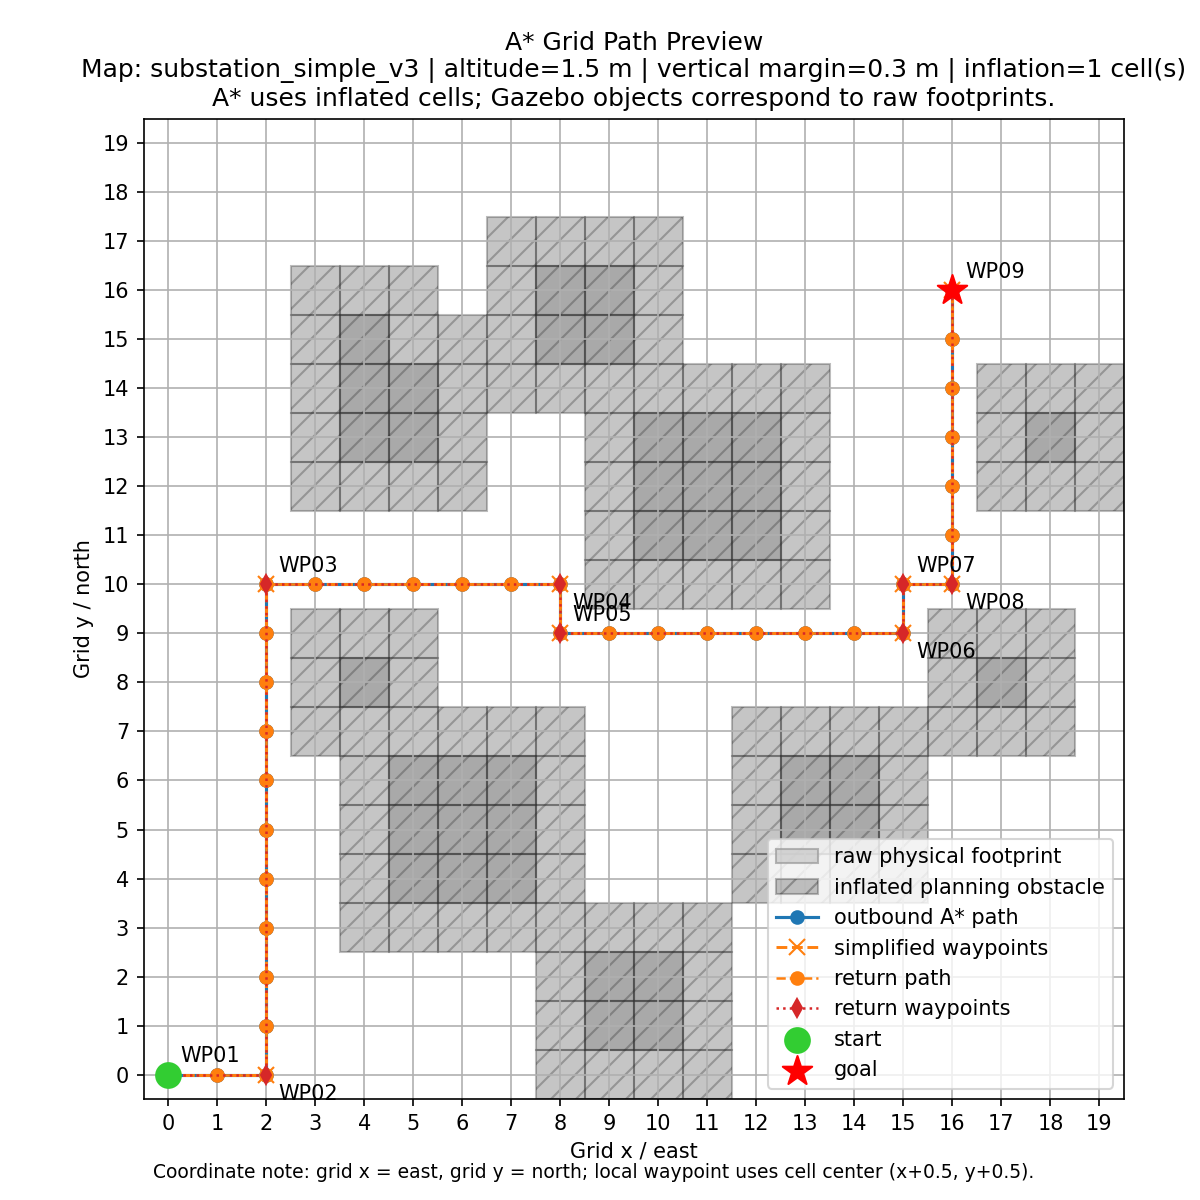
- Simulation: PX4/Gazebo flight with A* routing and local replanning.
- Sensor tools: LiDAR and camera recording, replay and inspection.
- ML workflow: controlled scenarios, dataset preparation and repeatable model evaluation.
How I used AI
I used AI coding tools to develop and refine the platform, then reviewed the code and checked its behavior in simulation.
Current status
The research platform is implemented. Formal learned-model comparisons are ongoing; real-airframe validation has not been performed.
Example output
See the code, experiment workflow and current research status.
Start a conversation
Good questions lead to useful work.
Research, building something, or comparing notes.